How Do Autonomous Robots Navigate and Avoid Obstacles?
Explore LiDAR, cameras, localization, mapping, and path planning—and why a robot that succeeds in a demo can struggle in a changing room.
The short answer
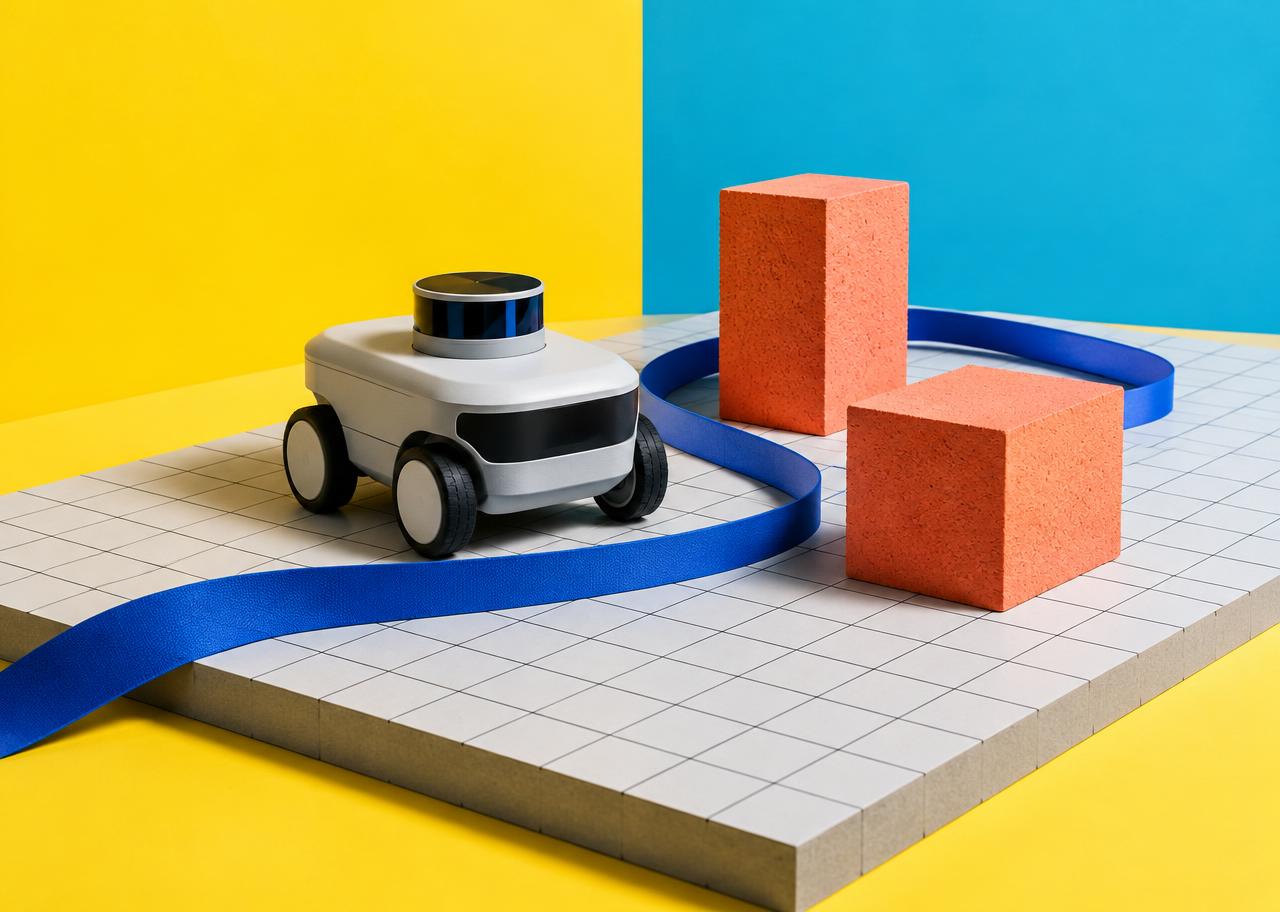
Autonomous mobile robots estimate where they are, build or consult a map, detect nearby obstacles, and choose a route they can physically follow. Navigation combines sensors, software, and safety controls; recognizing an object does not automatically mean the robot can avoid it safely.
Explore LiDAR, cameras, localization, mapping, and path planning—and why a robot that succeeds in a demo can struggle in a changing room.
01 / The story
Navigation begins with an estimate, not certainty
A robot needs a relationship between its own movement and its surroundings. Wheel motion, inertial measurements, cameras, and range sensors can contribute. Each has limitations: wheels can slip, visual features can disappear, and measurements can be noisy. Combining observations can improve an estimate without making it infallible.
Nav2’s documentation separates state estimation, environmental representation, planning, and control. This is a useful public framework for explaining mobile navigation, not proof that every commercial robot uses Nav2. Robots have different shapes, sensors, and operating areas, so a successful indoor wheeled platform does not establish capability on stairs or outdoors.
02 / The story
LiDAR and cameras provide different information
LiDAR uses light-based ranging to measure distances. Cameras record appearance, and depth cameras can provide distance information alongside images. Nav2’s sensor guide describes common inputs including laser scans, point clouds, images, and inertial information. Software must interpret these readings in the correct position and orientation relative to the robot.
Neither sensor type wins every setting. Cameras can be affected by lighting and lack of visual texture; range measurements can be affected by surfaces, geometry, and sensor coverage. Cost and compute requirements vary by product. An expensive sensor is not a complete safety system, and one missed object can matter more than an attractive map visualization.
03 / The story
Localization and mapping answer different questions
Localization estimates where the robot is in a reference frame or map. Mapping builds a representation of the environment. Simultaneous localization and mapping, or SLAM, addresses both while the robot moves. A stored map is useful but can become outdated when furniture, doors, or working areas change.
A map for navigation need not be a photorealistic reconstruction. It may record occupied areas, usable space, and regions to avoid. Nav2 costmaps add information relevant to route planning, including space near obstacles. Empty-looking cells should not be confused with a universal guarantee that the robot’s body will fit or that an unseen hazard is absent.
04 / The story
Planning chooses a path; control makes movement happen
A planner selects a route toward a goal. A controller turns that route into motion commands consistent with the robot’s movement constraints. A wide robot needs more clearance than a point on a screen, and a turning vehicle may not follow a sharp corner. Stopping distance also matters when obstacles move.
Local observations can trigger a change in route or a stop. Dynamic obstacles make the problem harder because the map is only a snapshot. A person stepping into the path can invalidate a previously reasonable plan. Safe operation therefore needs a response to uncertainty and sensor failure, not merely a route around blocks in a controlled demonstration.
05 / The story
Autonomy has an operating boundary
An autonomous robot can perform a bounded task without continuous steering while still needing supervision, maintenance, or help with unusual conditions. Navigation, object identification, manipulation, and conversation are separate capabilities. A robot that can name an object may be unable to navigate safely around it or interact with it.
This 2026 guide concerns educational, civilian navigation concepts and does not provide deployment certification or instructions for harmful use. It does not promise human-level spatial understanding in 2027. Experimental semantic navigation may add context, but demonstrations need evaluation under changing light, layouts, people, and failure conditions before broad claims are justified.
A closer look
A practical way to judge the claims
For a civilian robot demonstration, ask what happens when a sensor is blocked, a route becomes unavailable, or the robot loses its position estimate. The answer should include a safe fallback and a responsible operator, not just a successful video.
Use manufacturer instructions and controlled evaluation when considering a real device. Do not bypass safety functions or experiment around people based on a conceptual article. Public software documentation explains design components; it does not certify a complete robot for a specific environment.
Put it to work
Assess a navigation claim
Look for the operating conditions and failure response.
0 of 5 considered
These questions are editorial guidance, not a product score or verified assessment.
Keep learning
Further reading
- What Is Sensor Fusion? How Drones Combine Data From Multiple Sensors
Qlauson · Defense Technology
- How Do Open-World Video Games Create Realistic Cities?
Qlauson · Gaming Technology
- Nav2 documentation
External resource · Official ROS 2 navigation documentation covering state estimation, sensors, mapping, planning, and control. Opens in a new tab.
Read next
Can Your Laptop Run AI Locally? Memory, Speed and Real Costs
Can you run AI locally on a laptop? Compare model downloads, RAM, GPU memory, 70B limits, offline privacy and real costs before buying new hardware.
Continue readingNewsletter
Get new Qlauson stories by email.
An occasional email when we publish a new guide or update an important one. No unrelated promotions, and you can unsubscribe from any email.